
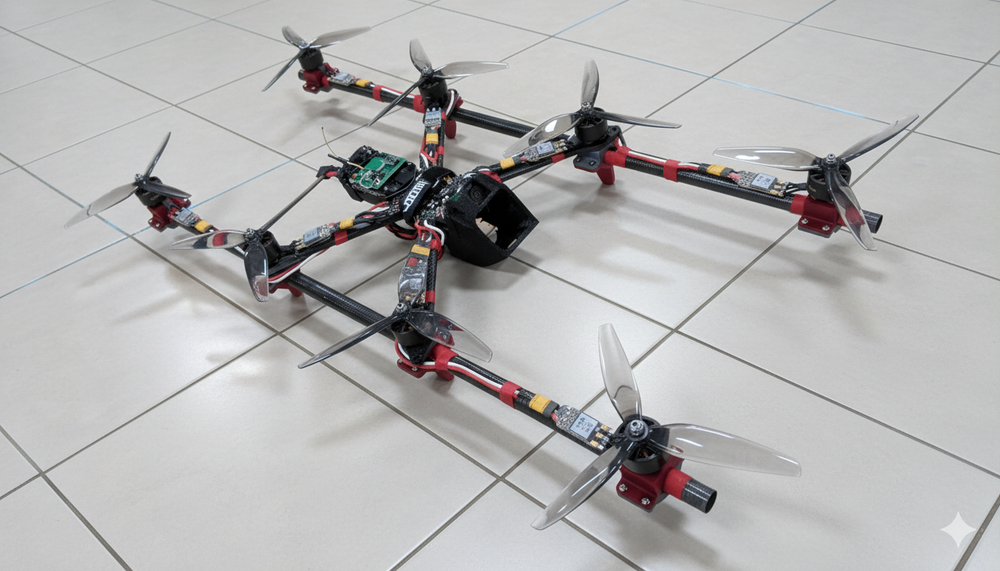
H-Frame Modular Payload Drone Development
Objective: Develop a compact, eight-motor modular drone that carries heavy payloads and flies safely in tight indoor spaces.
Client: Drone Racing League (DRL)
Role: Lead Mechanical Engineer / Hardware Prototyping Lead
Scope: Frame architecture, propulsion layout, vibration control, FEA, and rapid prototyping
Tools: SolidWorks, SolidWorks Simulation, carbon fiber tube, 3D printing (PA-CF, PETG-CF)
Overview: Indoor venues such as arenas, warehouses, and film studios need drones that can lift real payloads but still fit through a standard doorway. The answer was a narrow H-frame octocopter, a layout rarely used in the industry but chosen on purpose for modular payloads and tight-space flight.
The goal was a lightweight yet rigid frame that handles heavier payloads while staying stable and maneuverable in confined spaces, and that can be reconfigured quickly for different payloads and missions.
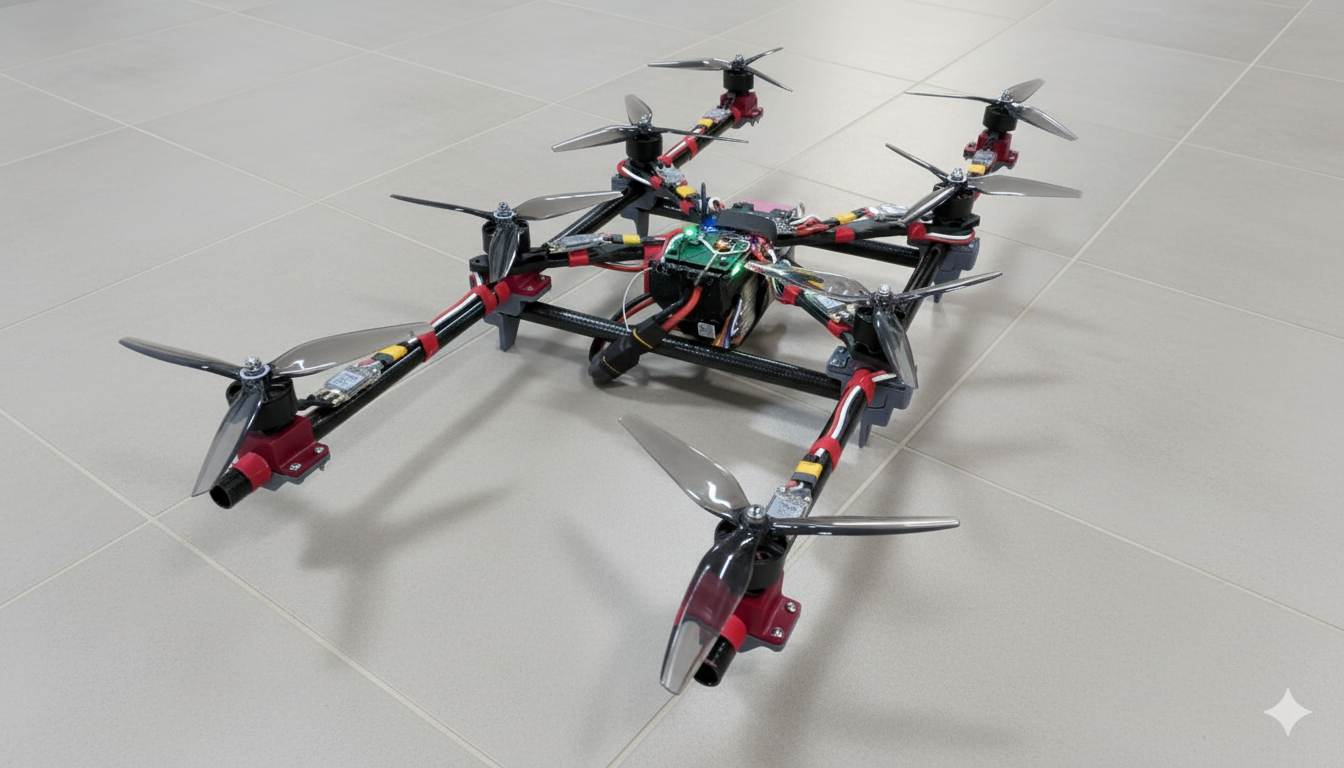

Maiden Test Flight
Frame Architecture
The H-frame maximizes thrust and payload capacity while keeping the aircraft narrow. The main longitudinal and lateral beams are carbon fiber tubes, chosen for their stiffness-to-weight ratio and vibration damping, and the modular tube system allows quick changes to motor layout, payload size, and thrust distribution.
Custom 3D-printed joint brackets act as both structural connectors and vibration isolators, with polyurethane dampers wrapped around the tubes to absorb mid- to high-frequency vibration from the motors and propellers. Combining printed parts with aerospace-grade composites produced a durable platform that is easy to modify.
Propulsion & Payload Handling
Eight motors double the thrust of a conventional quadcopter and spread the load evenly across the structure, adding the redundancy needed for professional cinematography, mapping, and LiDAR scanning.
Each motor sits in a modular printed housing built into the bracket system, with quick-swap mounts and wire channels. This keeps motor alignment accurate, simplifies assembly and maintenance, and keeps the center of gravity balanced for different payloads.
Solving Frame Vibration
Early test flights showed excess vibration through the carbon fiber frame, causing sensor noise and control instability. It was solved in three steps:
FEA in SolidWorks Simulation to find high-stress flex zones
Redesigned printed brackets with higher torsional stiffness
Custom damping inserts (urethane-infused polymer rings between bracket layers) that cut resonant vibration by more than 30% in bench tests
The refined frame is stiffer yet lighter, needs no external dampers, and carries payloads beyond its original design target without compromising handling.
Rapid Prototyping
All custom parts were modeled in SolidWorks and 3D printed in PA-CF and PETG-CF for dimensional stability and heat resistance. Each version was bench tested and flown, with arm lengths, bracket infill, and damper hardness tuned between iterations to balance stiffness and flexibility.
Results
Proved a narrow, high-payload multirotor that fits through standard doorways
30%+ reduction in resonant vibration
A modular, easy-to-assemble platform ready for cameras, sensors, and communication payloads
The design approach carried into DRL's next-generation performance platforms